Robotics Software Engineer

Ashrith Edukulla

I build perception systems for robots that operate where the data is messy.

B.S.E. Robotics, University of Michigan · Expected December 2027 · Ann Arbor, MI

Open-set detection underwater, multi-camera fusion into 3D, real-time VLA inference on vehicle hardware, and learned navigation policies that hold up in environments they haven't seen. I care about the measurable part: 30% over baseline, 78% success rate, or it didn't work. It's all C++ and Python, profiled and tested down to the edge device it runs on.

Ashrith Edukulla
3.8/4.0
GPA · Robotics
4
Courses as TA

News

About

I am a Robotics undergraduate at the University of Michigan who spends most of his time writing the software that makes robots see, decide, and move. Right now that means an end-to-end autonomous driving stack at NiFT and world-model navigation at the Scalable Spatial Intelligence Lab, after a summer building underwater perception at Moby Robotics.

I like the parts of the problem where correctness is measurable. A detector is 30% better than the baseline or it isn't; a navigation policy hits 78% success on held-out scenes or it doesn't; inference fits the latency and memory budget of the edge device or it doesn't ship. So a lot of my work is evaluation infrastructure, benchmarking harnesses, and profiling: the scaffolding that turns a promising idea into a claim you can defend.

The systems I enjoy most cut across layers: a multi-camera fusion pipeline that has to reconcile 360° imagery with stereo depth, a planner that switches sensing modes based on what it can currently observe, a safety layer that must deterministically override a learned policy. Getting those right is as much software engineering (interfaces, tests, reproducible environments) as it is robotics.

I've also taught four robotics courses as a teaching assistant, which has made me a much better debugger of other people's systems and a much clearer writer about my own.
What I Work On

Perception & Computer Vision

Open-set detection, multi-camera sensor fusion, stereo depth, and 3D reconstruction from real field data.

Moby Robotics · Event-Optical Fusion

Navigation & World Models

Long-horizon navigation with spatial memory, language-conditioned goals, and predictive representations.

Scalable Spatial Intelligence Lab · ObjectNav

Planning & SLAM

Coverage and frontier exploration, occupancy mapping, and state estimation under partial observability.

FRoG Lab · MBot SLAM

Systems & Infrastructure

ROS 2 and Dockerized evaluation stacks, reproducible benchmarks, profiling, and real-time edge deployment.

CARLA SFF · Habitat pipelines

Education

University of Michigan

University of Michigan, Ann Arbor

Aug 2024 – Dec 2027 (expected)

B.S.E. in Robotics · GPA 3.8 / 4.0

Honors: 4× University Honors · 4× Dean's List · Academic Excellence Award

Coursework: Data Structures & Algorithms, Deep Learning, Computer Vision, SLAM & Navigation, Controls, Robot Operating Systems, Dynamics & Vibration, Intro to Electrical Circuits

Current: Machine Learning, Intro to Reinforcement Learning, 3D Robot Perception, Autonomous Driving

Experience

Industry & Research

NiFT logo

NiFT

Aug 2026 – Present

Co-Team Lead · Robotics ML Engineer · Autonomous Shuttle

  • Co-lead the NiFT Autonomous Shuttle team, developing an end-to-end autonomous driving stack spanning planning, localization, control, and safety for multi-camera/LiDAR shuttles on NVIDIA AGX Thor.
  • Lead deployment and real-time optimization of NVIDIA Alpamayo 1.5/2, accelerating VLA inference via TensorRT Edge-LLM, FP8/INT8 quantization, CUDA Graphs, KV-cache tuning, and zero-copy pipelines.
  • Integrate Alpamayo into planning and control, linking multi-camera perception and 6.4 s waypoint trajectories to deterministic tracking, safety controls, and p50/p95/p99 latency profiling.
Moby Robotics logo

Moby Robotics

Jun 2026 – Aug 2026

Perception Machine Learning Engineer

  • Built underwater perception systems for nodules, marine life, and open-set objects, reaching 30% better detection than a vanilla VLM baseline, trained on real field data collected during at-sea deployments.
  • Developed a multi-camera sensor-fusion pipeline combining 360° imagery, stereo depth, and 3D reconstruction to improve spatial consistency for autonomous underwater mapping and navigation.
  • Profiled and optimized perception workloads on resource-constrained edge compute, balancing detection accuracy, inference latency, and memory for real-time deployment on embedded systems.
University of Michigan

Scalable Spatial Intelligence Lab

Mar 2026 – Present

Researcher · Navigation · Michigan Robotics

  • Developed a latent world-model navigation system reaching 78% ObjectNav success on HM3D, improving generalization over the OpenFrontier baseline through spatial memory and learned planning decisions.
  • Implemented a long-horizon navigation stack combining visual observations, language-conditioned goals, episodic memory, and predictive world-model representations for sequential decision-making.
  • Built Habitat evaluation pipelines benchmarking agents across unseen environments on success rate, path efficiency, and compute-performance tradeoffs, for fair and reproducible comparison.
Field Robotics Group logo

Field Robotics Group (FRoG) Lab

Dec 2025 – May 2026

Researcher · Perception & Planning · Michigan Robotics

  • Implemented hierarchical coverage planning for shipwreck inspection using BFS global search with locally biased RRT sampling, improving exploration efficiency.
  • Developed occupancy-grid and frontier-exploration algorithms to update coverage state and reduce redundant traversal under partial observability and noisy underwater sensing.
  • Built a multimodal mapping pipeline fusing sonar and stereo vision into a unified spatial representation, improving robustness of 3D scene understanding across varying conditions.
  • Designed state-driven switching between long-range sonar exploration and close-range stereo inspection, balancing global coverage against high-resolution local reconstruction.
University of Michigan

Synergic Adaptive Machines (SAM) Lab

Aug 2025 – Dec 2025

Undergraduate Researcher · University of Michigan

  • Researched macro- and micro-scale robot swarms under Prof. Steven Ceron to study collective motion and environmental interaction.
  • Developed decentralized control strategies for physical reconfiguration and emergent coordination.
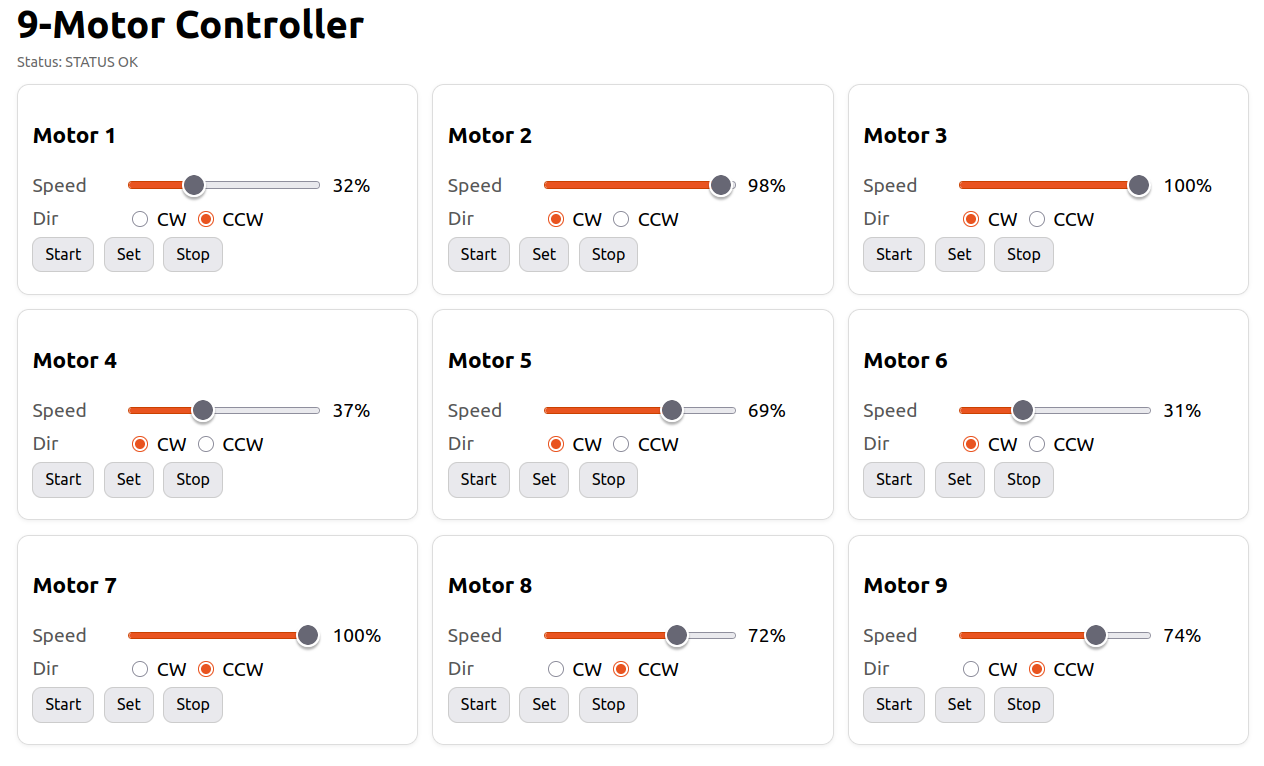
  • Built a C++ HTTP and serial control bridge with a browser UI for driving a 9-motor experimental array with real-time feedback.
University of Michigan

Michigan Mars Rover Team

Nov 2024 – May 2025

Embedded Software Engineer · Ann Arbor, MI

  • Programmed STM32 firmware to control servos, LEDs, and accelerometers for subsystem actuation and feedback.
  • Developed embedded drivers and ROS nodes for motor coordination and sensor data handling.
  • Contributed to navigation and control tuning for reliable performance in dynamic rover environments.

Teaching

University of Michigan

ROB 330

Aug 2026 – Present

Teaching Assistant · University of Michigan

  • Support MBot lab work in ROS 2 covering SLAM, localization, mapping, and waypoint navigation.
  • Debug full-stack robot systems with students, from sensor drivers and TF trees up through planning and control.
University of Michigan

EECS 467: Autonomous Robotics

Jan 2026 – May 2026

Teaching Assistant · University of Michigan

  • Mentored students through C++/Python/ROS labs covering perception, SLAM, sensor fusion, planning, and control.
  • Debugged end-to-end robot systems during labs and office hours, diagnosing software, algorithmic, sensor, and integration failures across the hardware/software stack.
University of Michigan

ROB 201: Robot Differential Equations

Aug 2025 – Dec 2025

Teaching Assistant · University of Michigan

  • Supported instruction in ODE modeling, linear systems, and control for undergraduate robotics students.
  • Led weekly office hours and problem sessions using Julia notebooks, simulations, and visualizations.
University of Michigan

ROB 101: Computational Linear Algebra

Dec 2024 – Apr 2025

Teaching Assistant · University of Michigan

  • Supported instruction in computational linear algebra (linear systems, least squares, and matrix factorizations), taught in Julia.
  • Held office hours and guided students through programming assignments and weekly problem sets.

Papers

Multi-Map Navigation World Action Models

In preparation

First author

Latent world models for long-horizon, language-conditioned navigation across multiple maps.

Multimodal Sensor Fusion for Shipwreck Coverage Planning

In preparation

Co-first author

Fusing sonar and stereo vision into a unified representation to drive hierarchical coverage planning for autonomous underwater inspection.

OceanSim 2.0: Underwater Robotics Simulator

OCEANS 2026

Third author

An Isaac Sim extension for underwater robotics research, adding subsea sensing, dynamics, and scene generation for repeatable experiments.

Projects

Selected work across perception, autonomous driving, navigation, SLAM, and multi-robot systems.

Featured Work

Flagship · AV Safety
10+
long-tail scenarios
SFF
deterministic override
ROS 2
closed-loop eval

CARLA · Docker · Safety Force Field

Vision-Language-Action Model: Safety Force Field

Integrated a learned driving policy with a deterministic Safety Force Field that overrides unsafe actions in multi-agent scenarios using collision-risk constraints. Implemented the potential-field safety algorithms plus unit tests validating deterministic behavior across diverse driving conditions, and wrapped it all in a Dockerized ROS 2 stack for closed-loop, reproducible evaluation with synchronized simulator and sensor interfaces.

CARLA ROS 2 Docker AV Safety

Perception & Multimodal ML

Event-Optical Fusion for Space Object Classification

Multimodal DarkNet53 + PointNet++ fusion for satellite detection, scoring 0.944 auPR. Paired with a spatiotemporal 3D CNN for trajectory prediction at ~91 ms batch inference.

PyTorch Event Cameras 3D CNN

Embodied AI

ObjectNav Behavior Cloning on HM3D

A ResNet18 + GRU navigation policy trained from 76K+ PIRLNav human VR demonstrations across 80 HM3D scenes, with truncated BPTT, 3.28x inflection weighting, and a custom dataset loader that bypasses Habitat's strict episode schema.

PyTorch Habitat Sim Behavior Cloning

Exploration & Planning

Ocean Frontier 3D Exploration: ROV Shipwreck Survey

A three-phase autonomous ROV mission: BFS sweep of unmapped voxels, RRT-biased centroid approach, and full next-best-view survey. Detects wrecks via vertical column clustering and fuses stereo depth with sonar into a real-time OctoMap.

ROS 2 C++ Sensor Fusion

SLAM

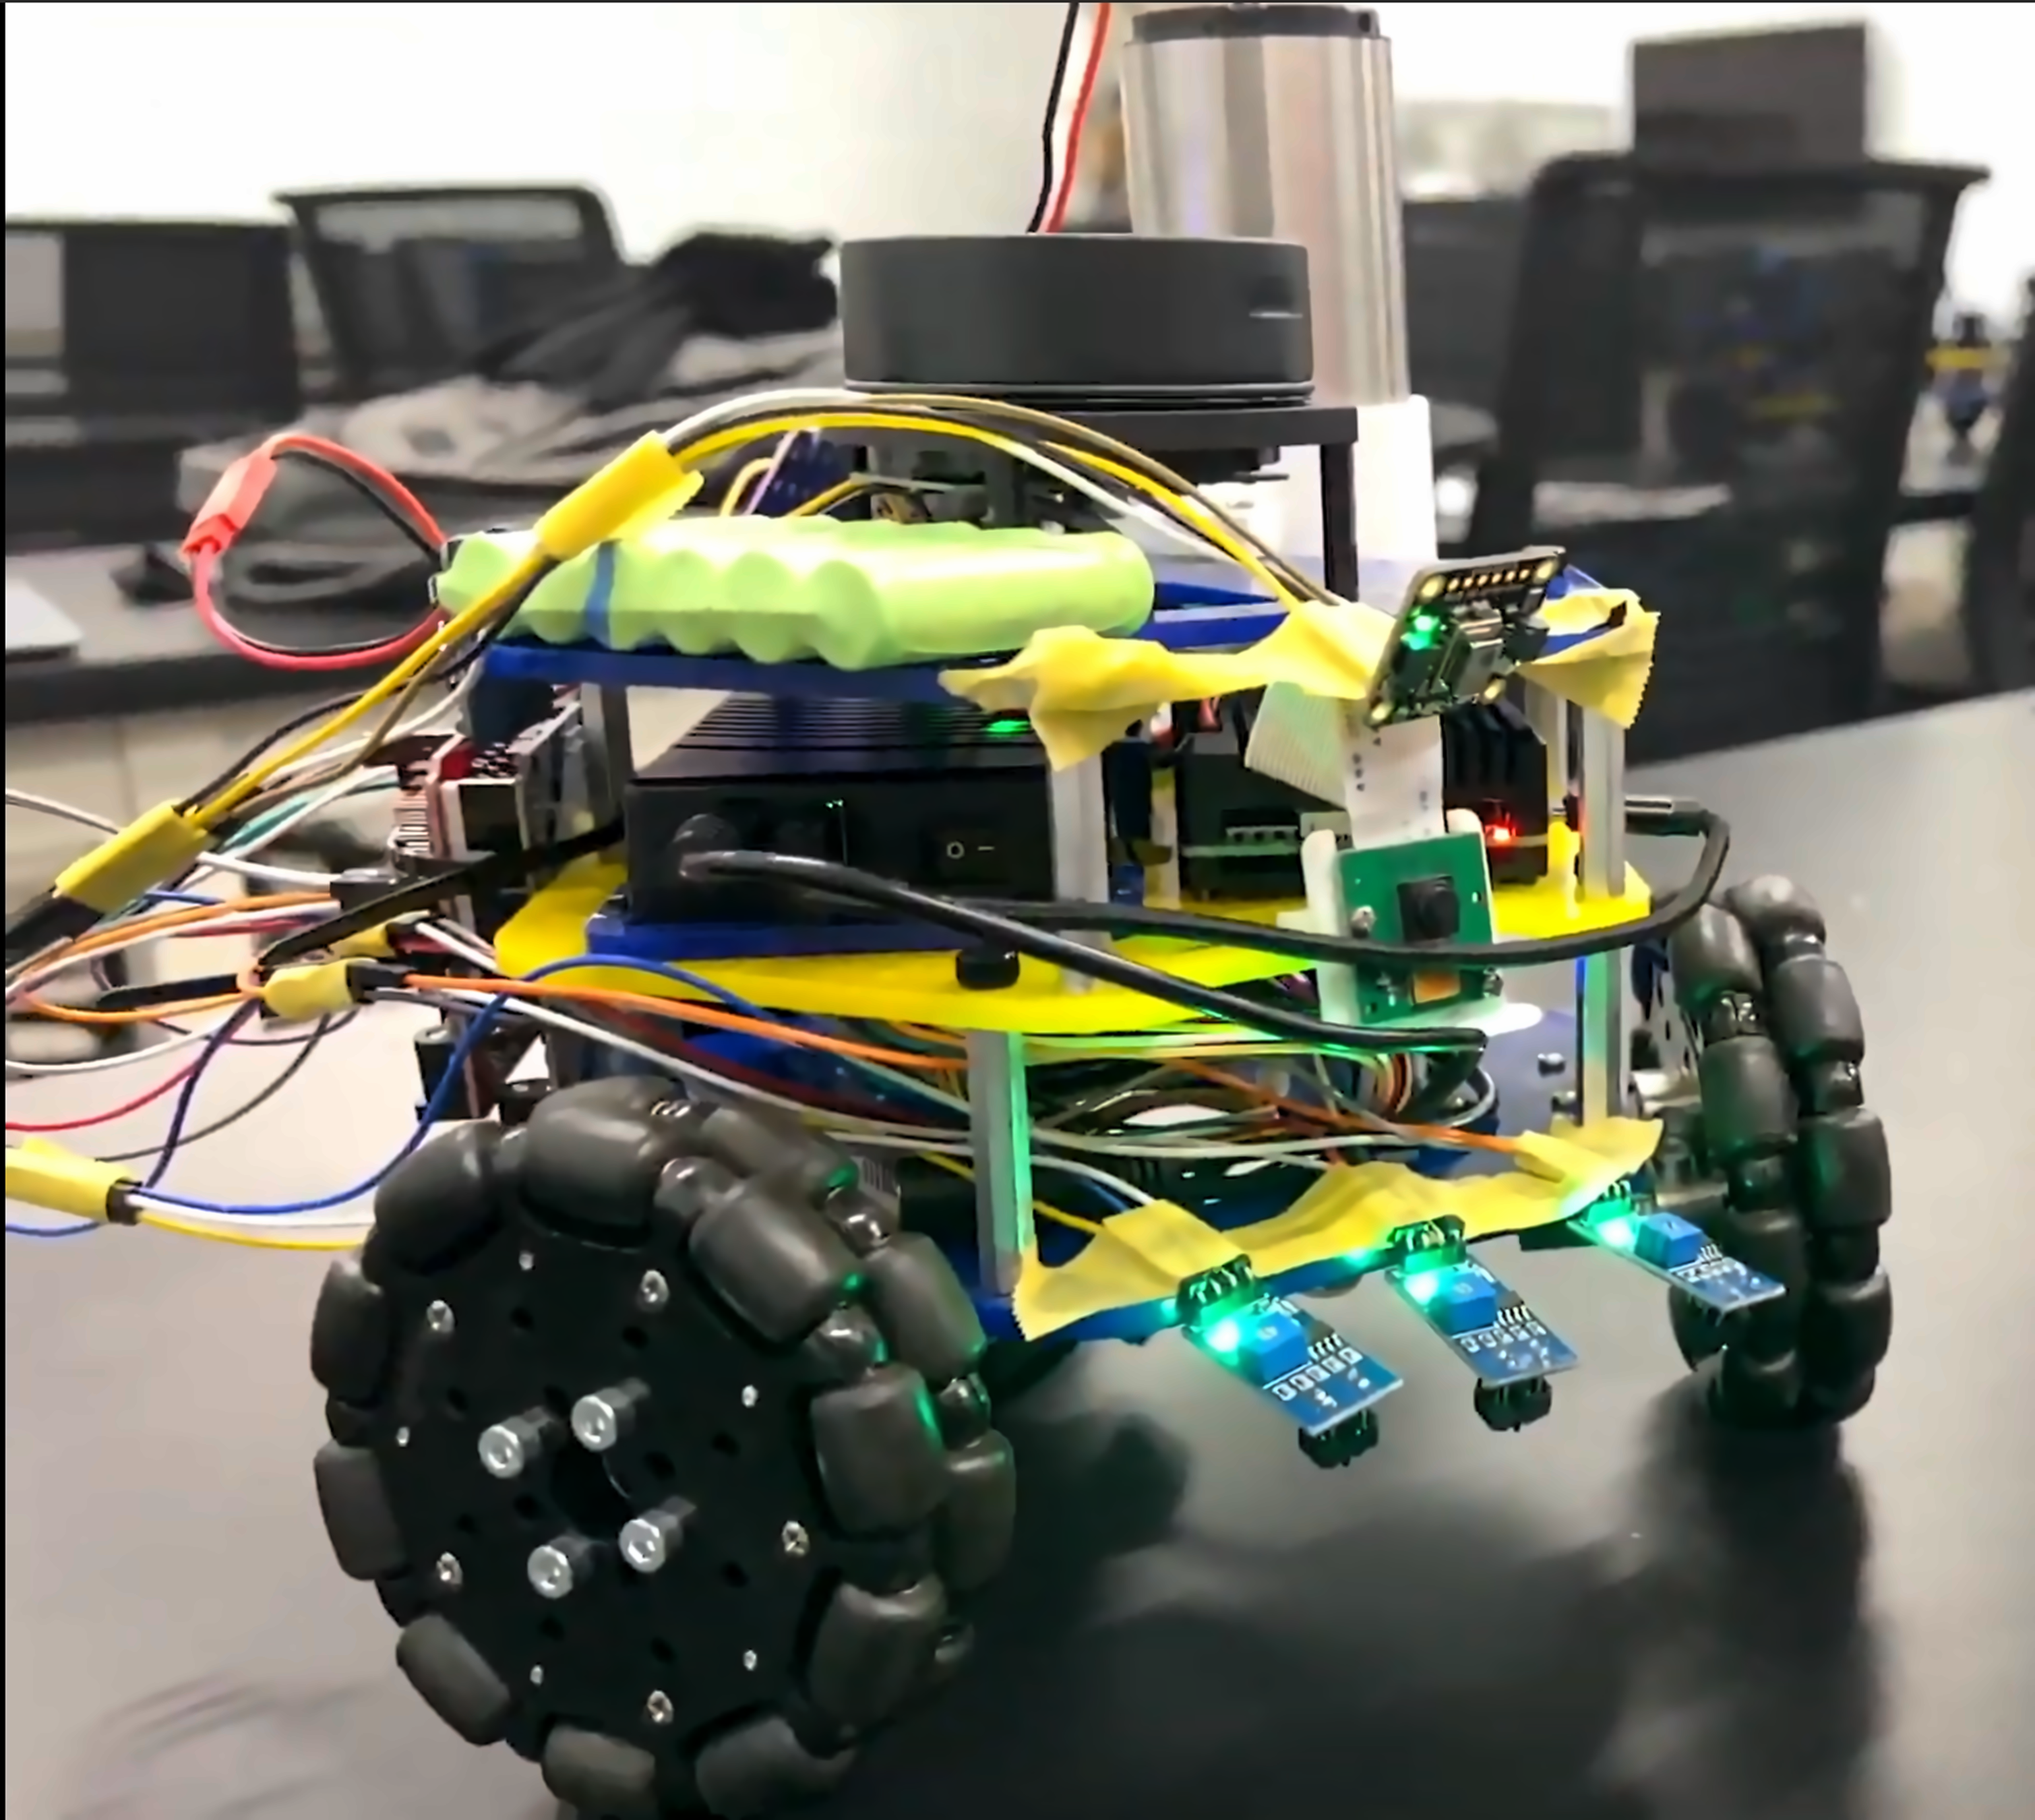
MBot Autonomous SLAM System

Full SLAM on the MBot platform: laser-based localization, occupancy-grid mapping, and autonomous exploration using frontier detection and A* path planning.

ROS 2 SLAM A*

More Projects

9-motor swarm control UI

Robotics Systems

9-Motor Swarm Control UI

A C++ HTTP + serial bridge and browser UI controlling a 9-motor array with real-time feedback and preset motion patterns.

Dynamics

Humanoid Leg Dynamics

MATLAB dynamic simulation of a humanoid leg, modeling joint torques, ground contact, and human-like gait.

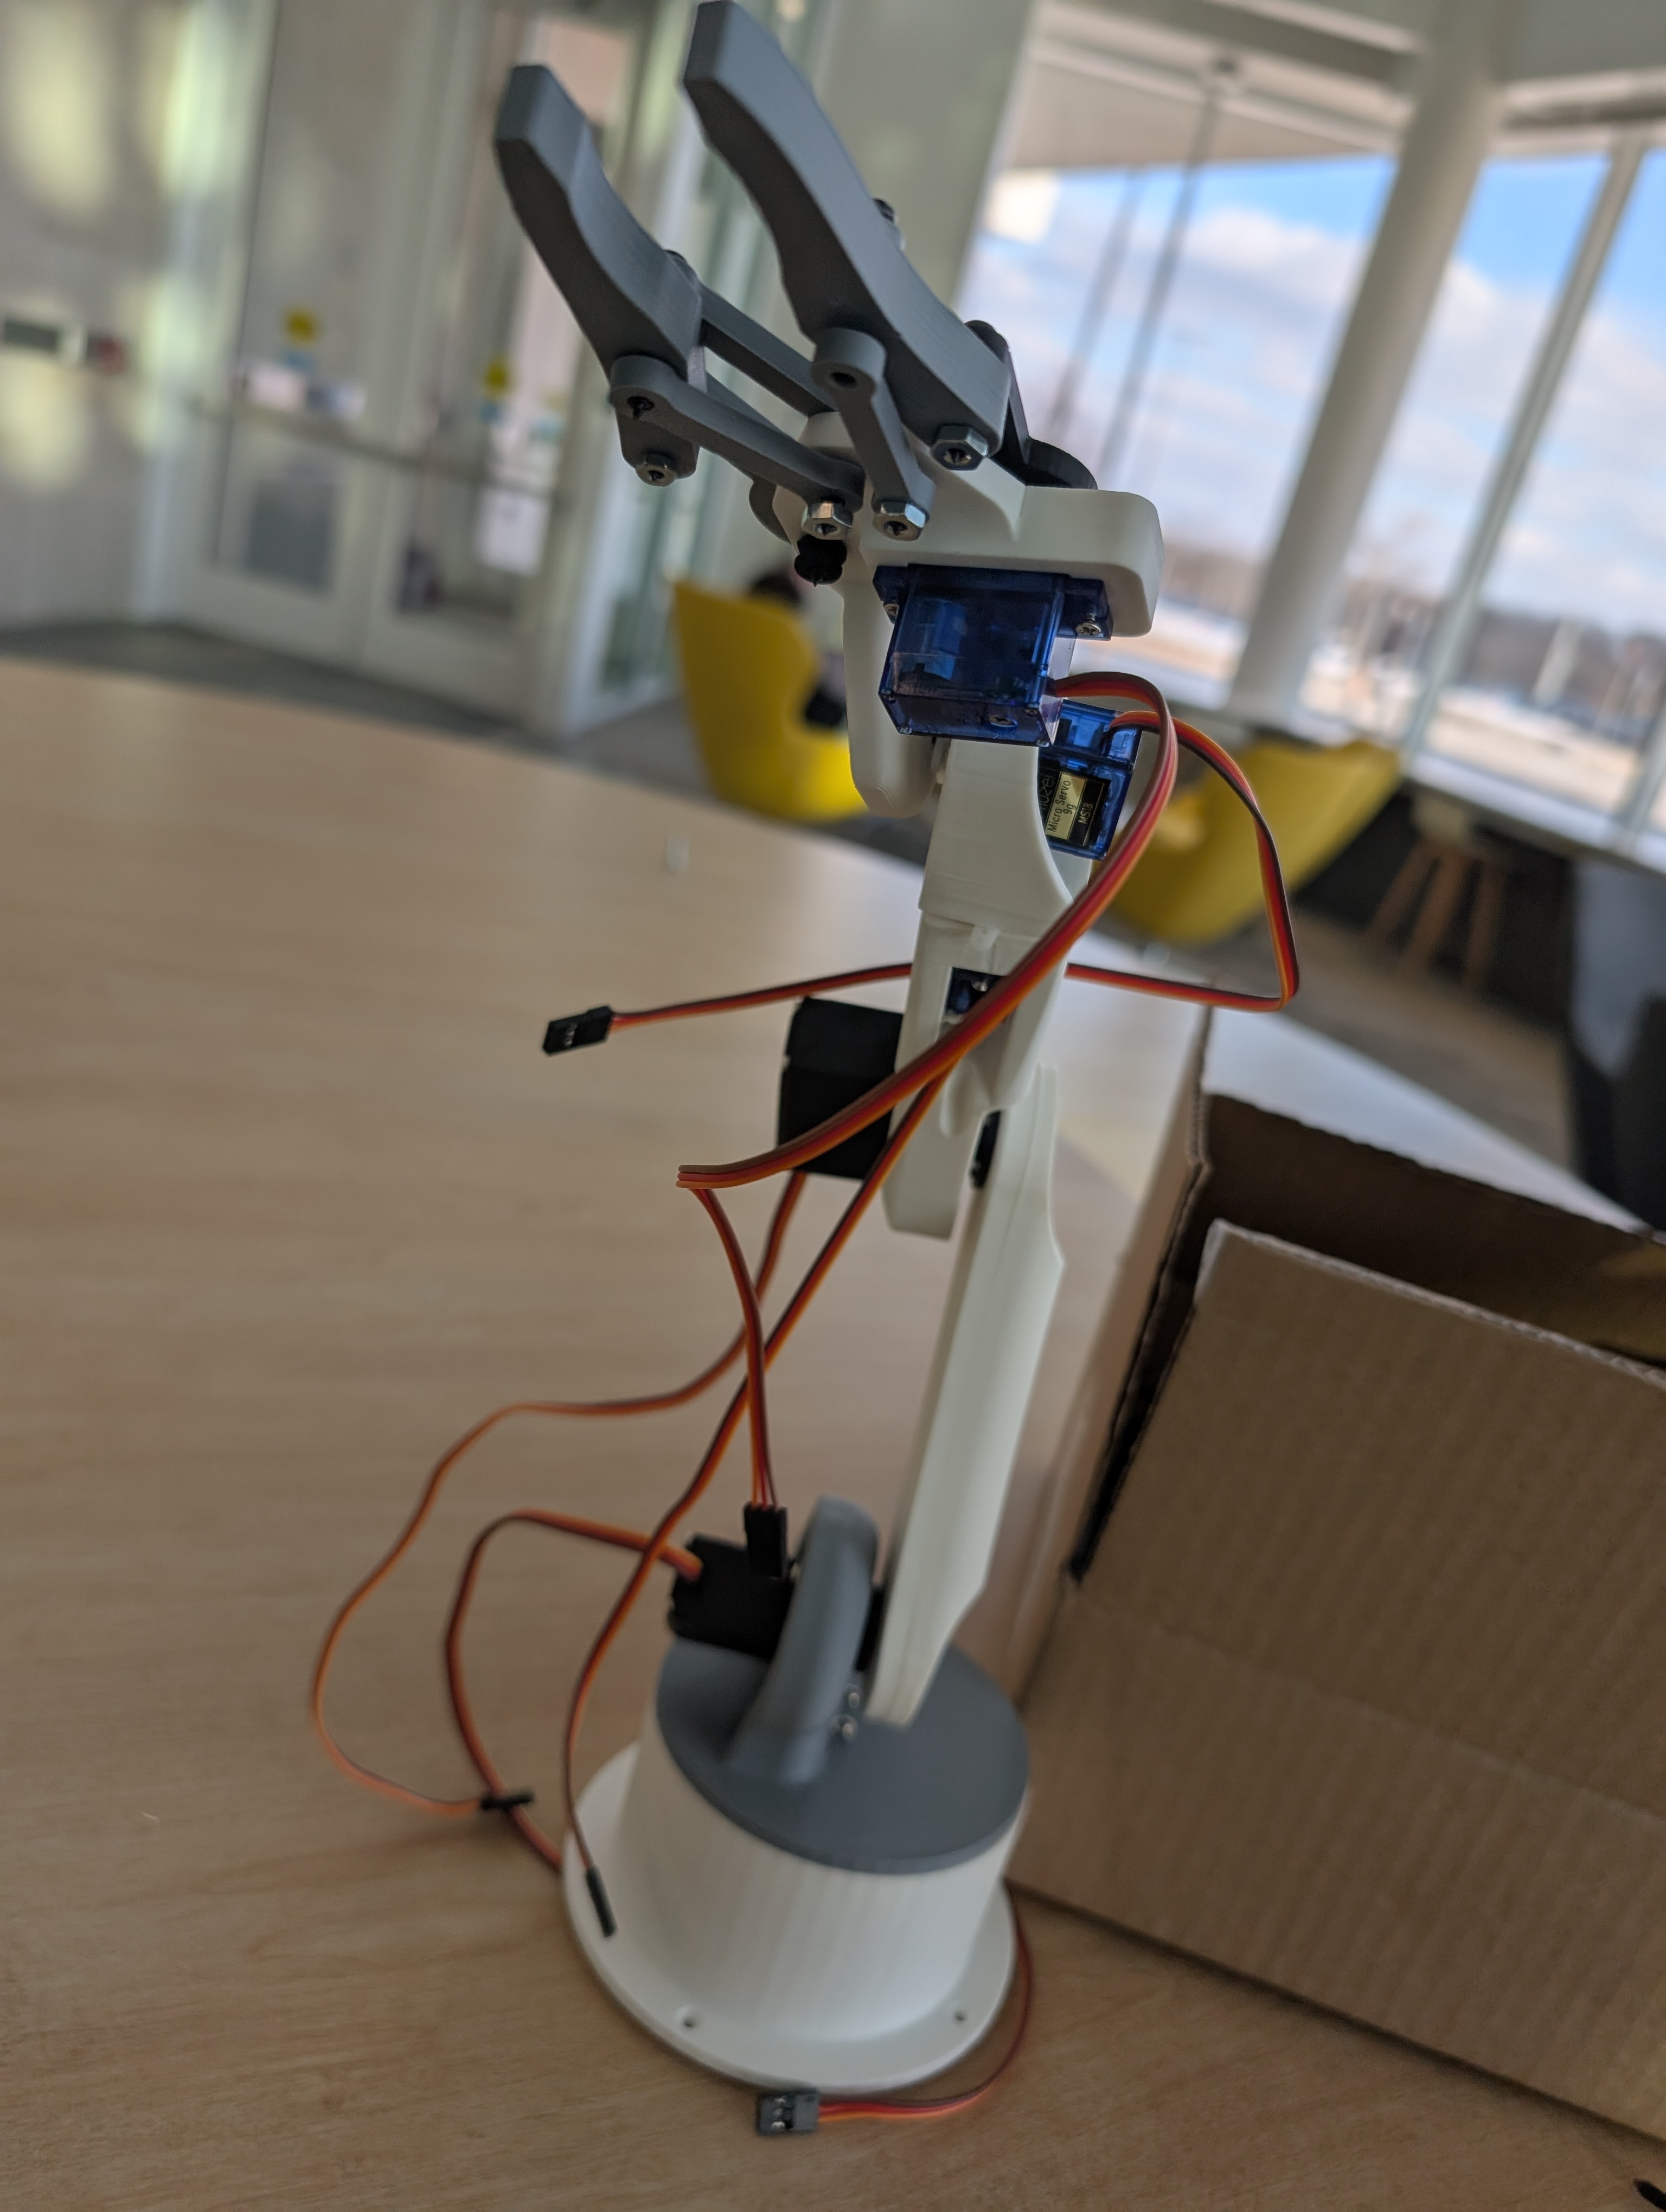
Motion-sensing robotic limb

Embedded

Motion-Sensing Robotic Limb

An accelerometer-based robotic limb with precise real-time finger control and motion sensing.

FROST black-ice detection robot

Sensing

FROST

Black-ice detection robot using sensor fusion; alerts pedestrians with LEDs and an audio module.

HighWay Go

Robotics

HighWay Go

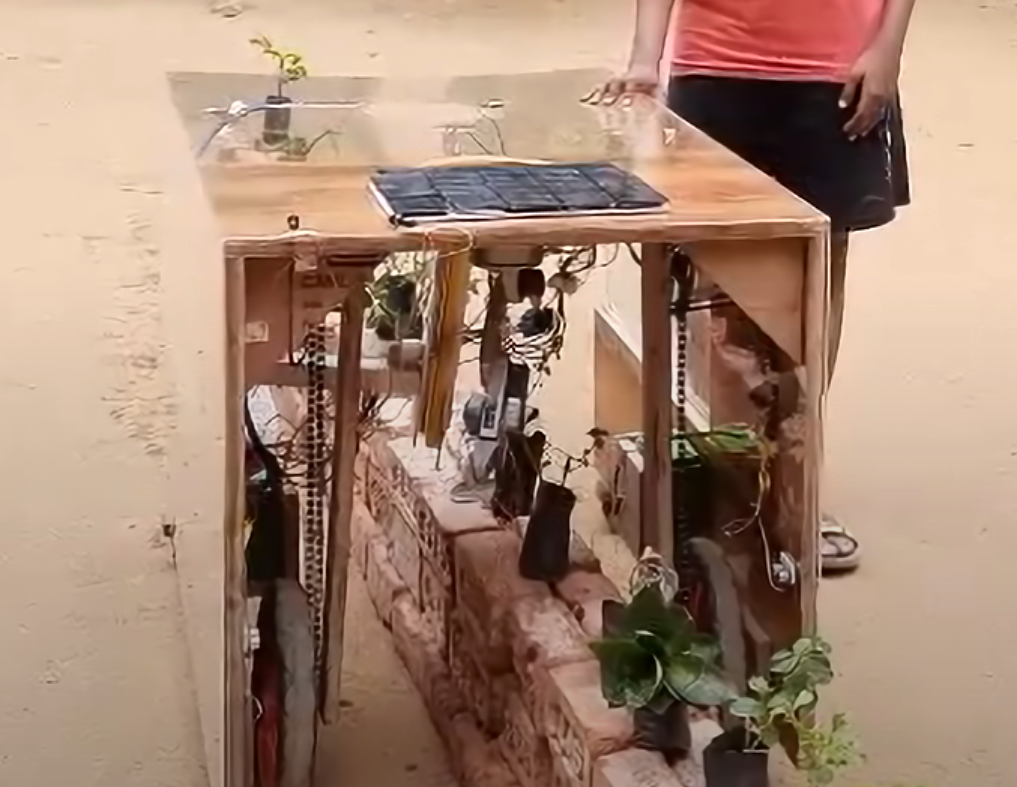
Solar-powered robot that waters plants on highway medians using a robotic arm.

SmartWheel

Energy

SmartWheel

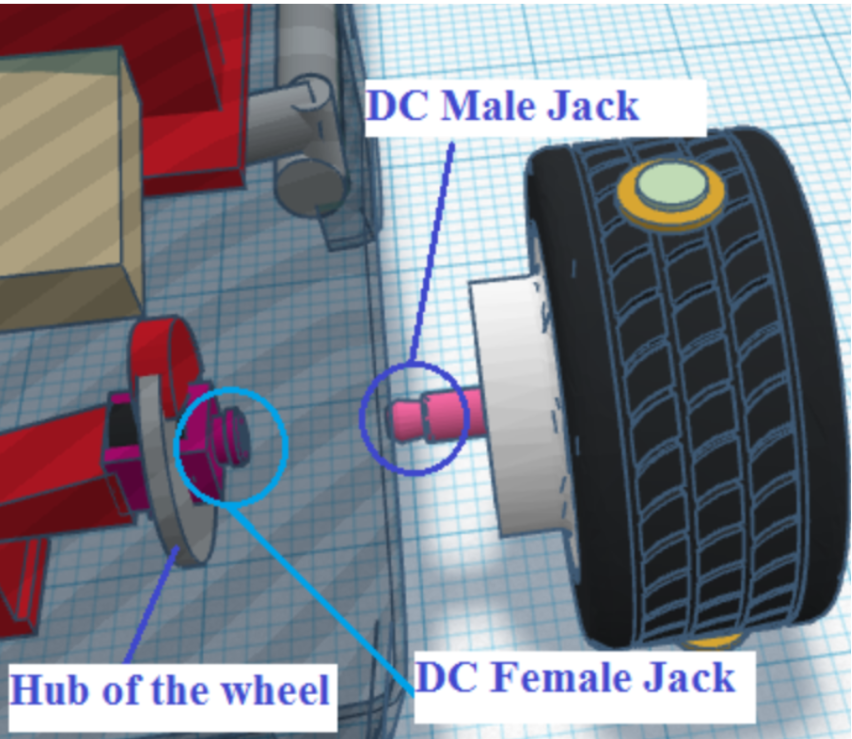
A dual energy-harvesting system drawing from pressure and heat to power EV batteries autonomously.

AutoFarm

Automation

AutoFarm

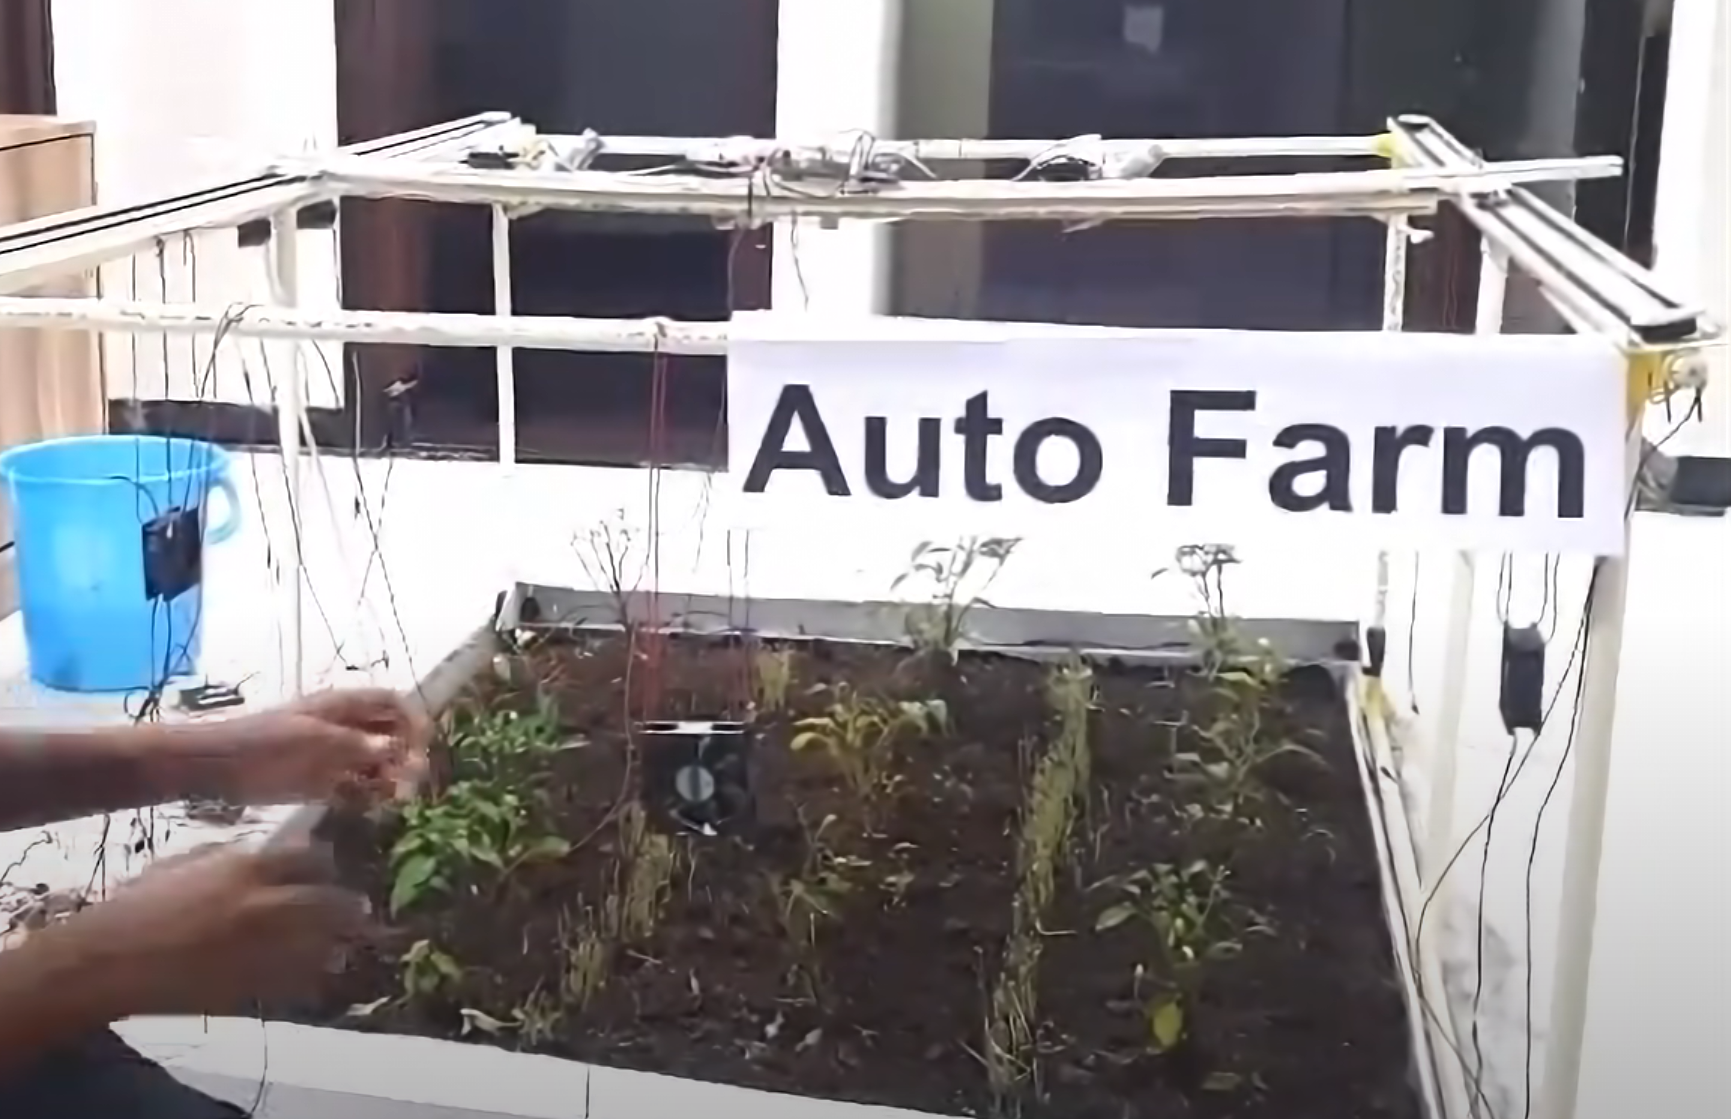
An agricultural robot that ploughs, sows, and waters, accelerating indoor crop growth with artificial light.

Skills

Languages & Systems

C++ Python Linux Git Docker ROS 2 MATLAB Julia

ML & Computer Vision

PyTorch OpenCV NumPy Stereo Vision Visual Odometry Multi-View Stereo 3D Gaussian Splatting 3D Reconstruction Point Cloud Processing

Algorithms

A* RRT Particle Filters EKF / UKF Occupancy Grids Frontier Exploration Trajectory Optimization SLAM Sensor Fusion State Estimation

Simulation

CARLA Isaac Sim Habitat Gazebo

Embedded & Tooling

STM32 Arduino I2C CMake gdb Profiling CUDA TensorRT Quantization

Awards

4×

University Honors

Awarded every eligible term at the University of Michigan.

4×

Dean's List

College of Engineering recognition for term academic standing.

★

Academic Excellence Award

University of Michigan, College of Engineering.

Let's connect

I'm always glad to hear from engineers, researchers, and teams building autonomy. The fastest way to reach me is email.

Email · school ashed@umich.edu
Email · personal eashrith@gmail.com
LinkedIn ashrith-edukulla
GitHub ashrith5321
X · Twitter @Ashrithed
Resume View PDF